Tianyi Sensor IOT Technology Co., Ltd
Sales Manager:Ms. Emily Wang
Cel,Whatsapp,Wechat:+86 15898932201
Email:info@fengtutec.com
Add:No. 155 Optoelectronic Industry Accelerator, Gaoxin District, Weifang, Shandong, China


Sales Manager:Ms. Emily Wang
Cel,Whatsapp,Wechat:+86 15898932201
Email:info@fengtutec.com
Add:No. 155 Optoelectronic Industry Accelerator, Gaoxin District, Weifang, Shandong, China
time:2025-04-08 10:13:39 source:Weather Station viewed:441 time
In the road structure system, from top to bottom are the surface course (with a thickness of about 15 centimeters), the base course (with a thickness of about 30 centimeters), the cushion course (with a thickness of about 25 centimeters), and the subgrade. The highway subgrade can encounter problems due to various factors. For example, human underground work activities such as mining and subway excavation; the presence of adverse geological structures and geological diseases beneath the subgrade; weak foundation soil; poor compaction degree of backfill soil; insufficient bearing capacity; leakage of underground pipelines; intrusion of groundwater, etc. These factors can lead to loose soil quality of the subgrade and excessive settlement of the stratum, and then gradually form subgrade diseases such as voids, cavities, and cracks. Moreover, under the repeated action of the vehicle load, the highway pavement will also be damaged gradually, showing phenomena such as cracking and mud boiling. In severe cases, it may even collapse and subside due to instability. Precisely because of this, the quality inspection of the road subgrade has received increasing attention from the construction party, the supervision party, and the designers.
In the past, the main methods for detecting road subgrade diseases were drilling or excavation, that is, drilling and coring on the road surface for detection. The greatest advantage of this method is its intuitiveness, but its disadvantages are also prominent. Firstly, it will cause a certain degree of damage to the road surface. Secondly, it can only infer the overall situation through individual points, and the detection accuracy is not high. It is difficult to accurately determine the shape and distribution range of the diseases, and it is impossible to comprehensively evaluate the quality of the subgrade. Thirdly, the detection speed is slow, the cycle is long, which is time-consuming and labor-intensive.
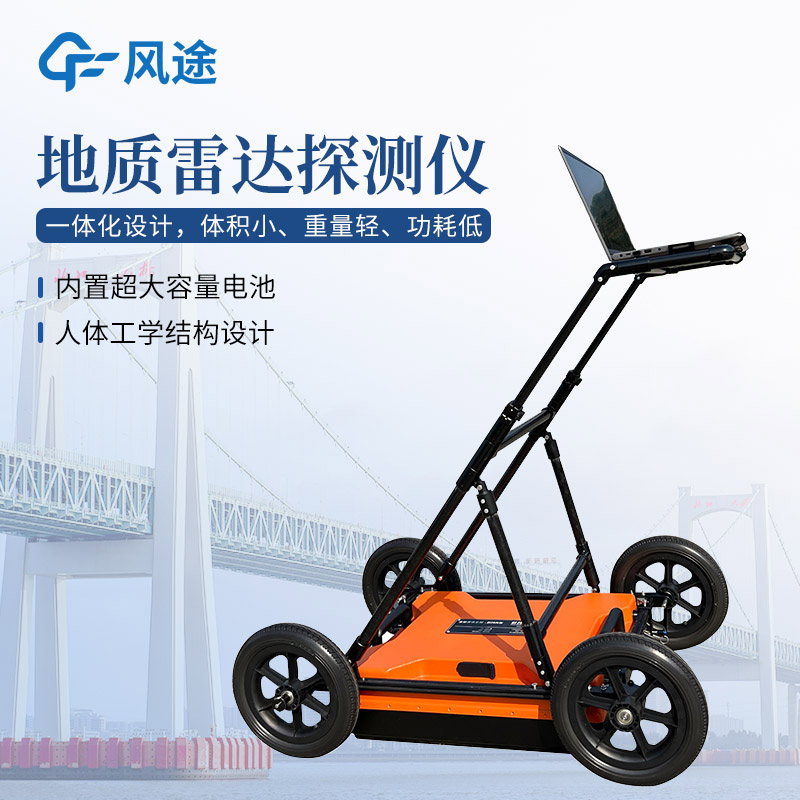
In contrast, using Ground Penetrating Radar technology to detect road subgrade diseases has advantages that traditional methods do not have. For example, Ground Penetrating Radar will not damage the road surface; it has extremely high resolution and reliable detection quality; it can move quickly, sample quickly, and display in real time, greatly improving work efficiency.
Since the mid-1990s, engineering technicians at home and abroad have carried out a series of research and exploration on using Ground Penetrating Radar technology for road subgrade quality inspection, including multiple fields such as the detection of the thickness of the asphalt layer, the quality inspection of the highway base course and subgrade, and the detection of subgrade diseases (such as subgrade settlement, mud boiling, cavities, weak bodies, cracks, etc.). In recent years, with the help of Ground Penetrating Radar technology, we have carried out a lot of research and practical work on the detection of road subgrade diseases and achieved rather satisfactory detection results.
During the detection of road subgrade diseases, Ground Penetrating Radar generally uses a shielded antenna with a frequency range of 100 to 900MHz. However, when it is necessary to detect karst caves or underground mined-out areas with a large burial depth (more than 20 meters), a rod-shaped combined antenna (MLF) with a frequency of ten to dozens of MHz is usually selected. The layout of the radar survey lines is generally carried out along the highway pavement, and the line spacing and point spacing need to be determined according to the nature of the project and the geometric shape of the detected object. In actual detection, the time window, gain size, and the number of superimpositions should be reasonably selected according to the quality of the on-site test signal to eliminate various electromagnetic interferences and obtain a more ideal test result.
Underwater Rescue Robot is equipped with a high-definition camera and imaging sonar, capable of transmitting real-time underwater footage back to the surface control station via either tethered or autonomous modes. With a maximum operational depth exceeding 300 meters, and outfitted with light...
In the daily operation and maintenance of photovoltaic power plants, testing equipment is a key tool to ensure power generation efficiency and system stability. Among them, the EL detector and I-V Curve Tracer are two widely used professional devices that evaluate the performance of photovoltaic mod...
Here's a little bit of knowledge: Bridges actually freeze more easily than road surfaces.Why is that?From the perspective of heat dissipation, the temperature difference between a bridge deck and an ordinary road surface is quite understandable. The road surface is directly built on the ground,...
With the arrival of the rainy season, frequent rainfall is prone to triggering geological disasters such as floods and landslides, posing a huge threat to people's lives and property safety as well as social and economic development. In order to timely grasp the rainfall situation, scientificall...


 Skype
 whatsapp
 mail